2026-W25 Industrial Sourcing Guide: 48V Power Integration and High-Stability Navigation Drives for AMRs
OEM Sourcing Update: STMicroelectronics launches L98GD8E 48V gate driver and low-drift ASM330LHHG1 IMU, shaping AGV/AMR drivetrain selection and ISO 3691-4 compliance.
By Jimmy Su · B2B Applications & OEM Program Lead
Last reviewed: 2026/06/21
MDX editorial page reviewed for buyer-facing scope, date boundaries, source traceability, and internal-link coverage.
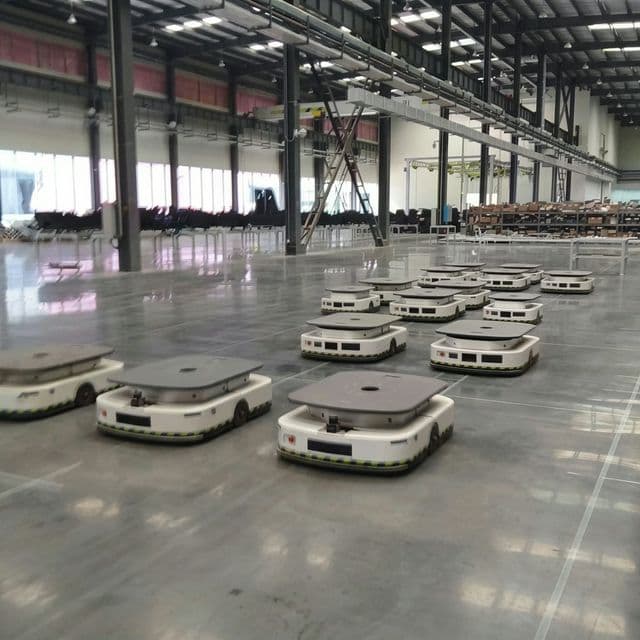
One-line buyer decision (as of 2026-06-21): When sourcing AMR/AGV drive units, OEMs must prioritize integrated 48V drivetrains featuring high-reliability gate drivers (e.g., L98GD8E) and dual-sensor fusion (safe encoder + low-drift IMU like ASM330LHHG1) to satisfy ISO 3691-4 Speed and Distance Monitoring (SDM) requirements.
Research window: 2026-05-22 to 2026-06-21. This update integrates the latest hardware releases from STMicroelectronics and industry compliance strategies to translate component changes into actionable procurement gates.
What Changed (Last 30 Days)
| Signal | Confirmed Date | Primary Source | What Changed | Buyer Implication |
|---|---|---|---|---|
| STMicroelectronics launched L98GD8E | 2026-06-04 | STMicroelectronics | Released a highly integrated 3-phase gate driver optimized for 48V automotive/industrial brushless motors. | Simplifies 48V integrated drivetrain designs, placing motor controllers inside the motor housing to reduce EMI. |
| STMicroelectronics launched ASM330LHHG1 | 2026-05-28 | STMicroelectronics | Released a high-precision, automotive-grade 6-axis IMU with low noise and high stability. | Provides the low-drift inertial feedback needed to detect and compensate for drive-wheel slippage on warehouse floors. |
| Maxon showcased Wheel Drive System | 2026-06-12 | Maxon Group | Highlighted MW modular wheel drive systems with integrated safety options supporting up to SIL 3 / PL e. | Allows direct plug-and-play connection to safe PLCs for dynamic Safe Torque Off (STO) and Safe Limited Speed (SLS). |
| Pilz published SDM implementation guidance | 2026-06-15 | Pilz International | Published design criteria for Speed and Distance Monitoring (SDM) to meet ISO 3691-4 safety requirements. | Forces buyers to purchase traction modules with redundant safe encoders rather than retrofitting external sensors. |
Technical Breakdown of 48V Drivetrain Integration
The transition from 24V to 48V power architecture is the leading trend in heavy-duty AMR and AGV design. Operating at 48V allows OEMs to double the power density without increasing cable thickness or heat dissipation, directly staying under the SELV (Safety Extra-Low Voltage) threshold.
The launch of the STMicroelectronics L98GD8E 3-phase gate driver on June 4, 2026, accelerates this integration. By offering programmable gate drive current and robust diagnosis (over-current, over-temperature, under-voltage), it allows drive-unit manufacturers to embed the electronic speed controller (ESC) directly onto the rear cap of the motor-gearbox assembly.
Additionally, on-floor wheel slippage remains a critical failure mode for natural SLAM navigation. When a polyurethane drive wheel traverses oil spots or dusty concrete joints, the wheel odometry drifts. By using low-drift, high-accuracy IMUs such as the ASM330LHHG1 (released May 28, 2026), navigation controllers can implement Kalman-filtered pose compensation to identify wheelslip in real time and maintain trajectory accuracy.
Implementing Speed and Distance Monitoring (SDM)
To comply with ISO 3691-4, system integration is moving away from static laser-scanner stop-zones to dynamic Speed and Distance Monitoring (SDM). The robot's safety controller (e.g., Pilz PSS4000 or SICK Flexi Soft) dynamically resizes safety zones based on current speed.
For instance, when an AMR runs at a maximum speed of 1.8 m/s, the protective warning zone must extend to at least 3.0 meters. As the laser scanner detects an obstacle (e.g., personnel), the controller sends a command to transition to Safe Limited Speed (SLS) at 0.5 m/s. If the robot fails to decelerate along the specified ramp, the safety controller activates Safe Torque Off (STO) immediately via the drive unit's safety encoders.
Integrating functional safety within the traction module simplifies validation. Instead of mounting external encoders or resolver converters, OEMs now source drive wheels with pre-certified dual-channel safety encoders (supporting PL d / SIL 2) directly aligned with the motor shaft.
Risks and Sourcing Boundaries
- Component Integration Delay: Although STMicroelectronics released the L98GD8E in June 2026, it will take 6 to 9 months for motor manufacturers (such as Dunkermotoren or Allied Motion) to design, test, and release commercial off-the-shelf integrated traction units featuring this specific driver chip.
- IMU Calibration Overhead: A high-precision sensor like the ASM330LHHG1 only outputs raw acceleration and angular rates. The navigation software team must invest substantial resources in custom Kalman filter calibration to prevent false-positive slip triggers.
- Safety Rating Bottlenecks: Standard planetary gearboxes do not possess functional safety ratings. If safety-rated braking is required, the brake and encoder assembly must be mounted on the input motor shaft, not the output wheel shaft, to maintain regulatory PLd traceability.
- Lead Time Pressures: Sourcing custom integrated 48V drive modules with built-in SIL 3 safety features still faces an average lead time of 10-14 weeks due to specialized certification queues.
Action Checklist
| Owner | Action item | Evidence to Request | Contract Trigger |
|---|---|---|---|
| OEM Engineering | Verify the drive unit's integrated motor controller supports 48V DC bus logic with overcurrent diagnostic protection. | Overload thermal log, 48V controller schematic, and maximum current ratings. | Engineering acceptance sign-off. |
| Robotics Architect | Integrate low-drift 6-axis IMU data (e.g. ASM330LHHG1) into the SLAM localization Kalman filter. | Odometer vs. IMU drift comparison chart under physical slippage tests. | Software architecture audit. |
| Procurement Manager | Mandate dual-channel safety encoders (PLd/SIL2 rated) in the traction module RFQ to support ISO 3691-4. | Safety certificate (TUV or equivalent) for the integrated encoder and brake. | Sourcing agreement annex. |
| Import Manager | Check compliance of the sourced components with EU Machinery Regulation (2023/1230/EU). | Certificate of Conformity for CE marking eligibility. | Regulatory compliance clause. |
FAQ
Why is 48V preferred over 24V for new AMR drive units?
48V reduces the electrical current by 50% compared to 24V systems for the same mechanical output. This minimizes I2R heat losses, reduces cabling diameter, and extends battery life, allowing AMRs to carry heavier payloads (e.g., >1000 kg).
How does the ASM330LHHG1 IMU prevent localization loss?
When AMR wheels slip on uneven warehouse floors, the wheel odometry incorrectly registers movement that did not happen. The low-drift IMU provides independent acceleration and angular velocity data, allowing the navigation system to detect and correct this slippage, maintaining accurate SLAM mapping.
What is Safe Torque Off (STO) in drive modules?
STO is a safety function that prevents force-producing energy from being starting-up or maintained in the motor. It enables safe operations next to humans by cutting power to the motor windings without shutting down the controller logic, allowing for fast restarts once the warning zone is clear.
How does the L98GD8E driver chip improve reliability?
It provides dedicated protection circuits for 48V power lines. Under stall torque or wheel blockage, it immediately disables the gate drives, preventing MOSFET burnout and ensuring the traction controller does not fail during operation.
Is ISO 3691-4 compliance mandatory in the US?
While ANSI/RIA R15.08 is the primary standard in North America, many global buyers mandate ISO 3691-4 compliance because it is the most rigorous framework for mixed-traffic fleet safety and is universally required for European deployments.
Sources
| Source Title | Institution | Date | URL |
|---|---|---|---|
| STMicroelectronics Announces L98GD8E Automotive-Grade 48V Three-Phase Gate Driver | STMicroelectronics | 2026-06-04 | https://newsroom.st.com/media-center/press-releases/2026/l98gd8e-pre-driver-48v-systems.html |
| High-Accuracy 6-Axis Inertial Measurement Unit (IMU) for Industrial Navigation | STMicroelectronics | 2026-05-28 | https://newsroom.st.com/media-center/press-releases/2026/asm330lhhg1-high-accuracy-imu.html |
| Wheel Drive System (MW) Specifications for Autonomous Mobile Robots | Maxon Group | 2026-06-12 | https://www.maxongroup.com/maxon/view/content/wheel-drive-system |
| Speed and Distance Monitoring (SDM) Design Guidelines for ISO 3691-4 Compliance | Pilz International | 2026-06-15 | https://www.pilz.com/en-INT/eshop/00106002237083/PSS4000-safe-motion |
| ISO 3691-4:2020 Industrial Trucks — Safety Requirements and Verification — Part 4 | International Organization for Standardization | 2020-04-15 | https://www.iso.org/standard/70660.html |