Specify the vehicle boundary before the motor
Gross mass, grade, wheel radius and acceleration determine straight-line wheel demand. Steering, scrub and load transfer remain separate validation work.
Model and exclusions ↓ AMRDriveUnit
Concept configurator + evidence guide · Reviewed 2 Nov 2026
Choose a vehicle example, adjust its mission, and get wheel torque, DC demand and a copyable engineering brief. Estimates support architecture discussions; component selection needs validation.
Configure your drive system ↓Read the decision guidePallet AMR: 1,000 kg payload (48V) · Examples are hypothetical, not tested customer installations.
Range: 50–12000 kg. Required.
Range: 30–3000 kg. Required.
Range: 0.2–4 m/s. Required.
Range: 0.2–5 s. Required.
Range: 0–20 %. Required.
Range: 100–450 mm. Required.
Defaults: 2-wheel differential, 48 V, 70% driven load, PMSM/planetary, 25°C, 16 h/day, 60% running. Safety and bus selections record requests; no certification or network timing is calculated.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Required selection. Validate availability with your supplier.
Range: 40–95 %. Required.
Range: -25–55 °C. Required.
Range: 4–24 h/day. Required.
Steady wheel torque
29.4 Nm
Per wheel at 3% uphill grade; not a thermal rating
Steady total DC current
22.4 A
Cruise load; excludes auxiliaries and steering
Downhill peak regen
3285 W
Electrical return estimate; battery acceptance unknown
Motor / inverter losses
93 / 43 W
Total steady losses; fixed efficiencies, no temperature prediction
Transmission losses
56 W
Assumed efficiency: 94%
Cruise-only scenario
215 Ah/day
Running fraction × hours; not a battery capacity recommendation
Model: rolling coefficient 0.018, grip coefficient 0.65, rotary inertia factor 1.12, motor efficiency 91%, inverter efficiency 96%. Deceleration = 1.2 × requested acceleration. These are declared model assumptions, not measured values. See equations and exclusions.
Published by AMRDriveUnit. First repository record: ; reviewed: . We review this guide every six months, or when sources or the model change. Report a correction.
Use the tool to frame a request; use the guide to decide what evidence is needed before hardware selection.
Gross mass, grade, wheel radius and acceleration determine straight-line wheel demand. Steering, scrub and load transfer remain separate validation work.
Model and exclusions ↓STO does not establish electrical isolation or a parking strategy. Request the drive safety manual and validate the complete vehicle stop sequence.
STO manufacturer guide ↓A single peak-power number cannot size a resistor. Record stopping energy, repetition rate, downhill duty and the battery charge-acceptance envelope.
Regen sizing guide ↓Check the implemented modes, process data, fault behavior and product-specific evidence. A configurator selection cannot confer SIL/PL achievement or guarantee cycle time.
CiA 402 profile scope ↓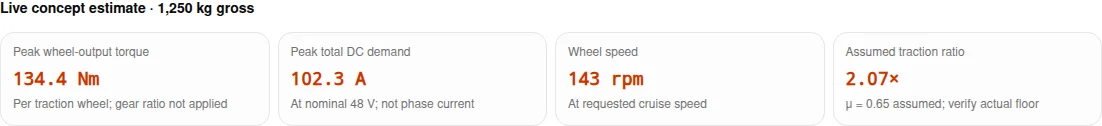
Decision framework, not a measured supplier comparison. Price, lead time and available ratings are unknown until quoted.
| Decision | Catalog / configurable assembly | Custom development | Evidence to request |
|---|---|---|---|
| Packaging | Prefer when mounting and wheel envelope already fit | Consider for envelope or load-path constraints | STEP model, bearing loads, cable bend envelope |
| Controls | Prefer a documented supported bus and mode | Consider for a missing interface or multi-axis coordination | Interface file, state-machine test, fault recovery trace |
| Commercial risk | Usually fewer design tasks if requirements fit; obtain quote | Budget integration, tooling, prototypes and revalidation | Separate NRE, unit price, MOQ and change-control terms |
| Service | Check spare availability and replacement compatibility | Define ownership of firmware, drawings and test fixtures | Lifecycle support, spare strategy and acceptance plan |
Scroll horizontally to compare columns; keyboard users can focus the table region.
Wheel counts describe the configurations supported by this tool. Other layouts require a separate model.
| Topology | Model count | Model boundary | Before release |
|---|---|---|---|
| Differential / dual swerve | 2 traction wheels | Equal sharing of forward tractive force | Measure turn scrub or steering torque and dynamic load distribution |
| Quad swerve | 4 traction wheels | Straight travel only; steering axes excluded | Verify traction sharing, steering inertia and synchronization |
| Mecanum | 4 traction wheels | Indicative forward demand only; no roller/vector model | Calculate lateral forces, roller losses and reduced available grip |
| Single steer-drive | 1 traction wheel | Drive wheel carries entered load fraction | Verify stability and load fraction throughout the route |
Scroll horizontally to compare columns; keyboard users can focus the table region.
Quasi-static straight-line estimates with fixed efficiencies and equal force sharing. SI units are used: mass m in kg, radius r in m, speed v in m/s, acceleration a = v / t in m/s² and grade angle θ = atan(grade% / 100). Let n be the traction wheel count and k = 1.12 the rotary inertia allowance.
Uphill force: Fsteady = m·g·(0.018·cosθ + sinθ); Fpeak = Fsteady + m·a·k.
Wheel output: T = F·r / n; rpm = 60·v / (2·π·r); total wheel power Pwheel = F·v.
DC input: Pdc = Pwheel / (ηgear·ηmotor·ηinverter); Idc = Pdc / Vnominal. Peak demand assumes full acceleration at cruise speed and is a concept envelope.
Steady losses: Qinverter = Pdc·(1 − ηinverter); Qmotor = Pdc·ηinverter·(1 − ηmotor); Qgear = Pdc·ηinverter·ηmotor − Pwheel. Their sum equals Pdc − Pwheel.
Downhill deceleration: Fbrake = max(0, m·(1.2a)·k + m·g·sinθ − 0.018·m·g·cosθ); Pregeneration = Fbrake·v·ηgear·ηmotor·ηinverter. Reverse-flow efficiencies are assumed equal; actual maps may differ.
Traction ratio: μ·fdriven·m·g·cosθ / Fpeak with μ = 0.65. This assumed available/required force ratio is not a verified safety margin.
Cruise-only daily consumption: Idc,steady × running fraction × operating hours. The fraction is an illustrative scenario, not an IEC thermal duty classification or a runtime prediction.
Out of scope: gear ratio selection, motor phase current, RMS/thermal rating, floor-test friction, stopping distance, stability, steering/lifting/auxiliary loads, low-voltage battery behavior, cable/fuse selection, contact pressure and safety certification. No temperature or tread formulation is inferred from wheel diameter.
All efficiencies below are concept assumptions, not verified component data. Temperature and speed dependence are excluded.
| Item | Tool treatment | What changes the decision |
|---|---|---|
| Rolling / grip coefficients | 0.018 / 0.65; fixed | Floor contamination, tread, load, wear and direction; measure on site |
| Rotating inertia allowance | 1.12 × translational acceleration force | Actual rotor/gear/wheel inertia and gear ratio |
| Transmission efficiency | Planetary 0.94; cycloidal 0.88; strain wave 0.82; direct/bearings 0.98 | Supplier efficiency map at the requested torque/speed |
| Motor / inverter efficiency | PMSM 0.91; BLDC 0.87; frameless 0.89 / inverter 0.96 | Motor-drive map, switching strategy, low-speed losses |
| Deceleration / duty | Deceleration = 1.2 × acceleration; running fraction 100%, 60% or 40% | Actual stop profile, acceleration frequency, RMS torque and idle demand |
| Safety, cable and tread ratings | Unknown; not calculated | Risk assessment, electrical design and supplier validation |
Scroll horizontally to compare columns; keyboard users can focus the table region.
For fixed input power, I = P / V. Nominal voltage is not the worst-case battery voltage.
| Choice | Potential benefit | Cost / failure risk | Acceptance evidence |
|---|---|---|---|
| Higher DC voltage | Lower current for the same electrical power | Different battery, insulation, protective devices and service procedures | Minimum/maximum battery voltage, transient limits and protection review |
| Integrated motor + inverter | Shorter phase wiring and fewer external parts | Shared heat path and replacement boundary | Thermal soak in the actual mounting and ambient conditions |
| Separate motor + inverter | Flexible inverter cooling and service access | Phase cable routing, EMC and connector count | Cable/EMC test and installation drawing |
| Regeneration path | Return deceleration energy where the battery permits | Charge rejection or bus overvoltage when full/cold/disconnected | BMS acceptance map and chopper pulse/average checks |
Scroll horizontally to compare columns; keyboard users can focus the table region.
Separate fleet commands, vehicle motion control, motor/inverter control and ground traction. Decide who owns tuning, firmware, safety integration and acceptance testing. A drive module specification should state which of these interfaces is included.
Use payload plus tare mass, not payload alone. Calculate uphill cruise and uphill acceleration separately. Equal load sharing is only a first approximation; turns, caster scrub and a wheel crossing a joint can change which module is limiting.
Wheel-output torque is force times radius. Gearbox efficiency belongs in the input-power conversion. Motor torque additionally needs gear ratio. The DC result is total battery-side current at nominal voltage, not phase current or a permissible cable ampacity.
On a downhill stop, gravity adds to braking demand while rolling resistance helps slow the vehicle. Measure battery charge acceptance at full state of charge and temperature extremes. Evaluate both pulse energy and average repetition duty before selecting a chopper or resistor.
Supporting source and scope ↓A requested STO level is an integration target. Achieved system performance depends on the exact certified components and their installation. Specify how the vehicle stops, how it stays stationary, and how stored electrical energy is isolated for service.
Supporting source and scope ↓The tool reports steady losses but has no thermal resistance, airflow, winding curve or enclosure model. Daily hours alone cannot establish a motor duty rating. Review RMS torque over the mission and test the final mount, especially in sealed or cold-storage installations.
Agree on supported operating modes, object mappings, watchdog behavior and recovery after a communication fault. CiA 402 defines drive behavior but implementations can differ. Measure the target timing on the intended master, firmware and node count.
Supporting source and scope ↓Request separate prices for NRE, prototypes, tooling, production units and spare support. Agree CAD approval, bench performance, vehicle integration and pilot acceptance gates. Delivery and certification status must be confirmed for the offered configuration.
Sources: CiA 402 profile overview, STO manufacturer guide and ISO public scope. The table is an integration checklist, not a conformity assessment.
| Boundary | Specify | Test / evidence |
|---|---|---|
| Motion bus | Modes, data mapping, update target, watchdog and timeouts | Interface files and measured timing with final node count |
| STO / safe motion | Required function and risk-assessment target | Exact variant certificate, safety manual and system validation |
| Holding brake | Holding load, incline, release power and wear limits | Holding verification; confirm whether dynamic stopping is permitted |
| Power isolation | Maintenance disconnect, discharge and stored-energy controls | Electrical review; STO does not provide electrical isolation |
Scroll horizontally to compare columns; keyboard users can focus the table region.
Use this list to turn a concept brief into a testable purchase requirement.
| Risk | Why the tool cannot close it | Minimum mitigation / alternative |
|---|---|---|
| Misuse: treating a ratio >1 as safe | Fixed friction and equal sharing omit real conditions | Test grip at worst route conditions; reduce acceleration or redesign traction |
| Thermal mismatch | Fixed efficiencies do not predict temperature or duty rating | Use RMS torque and component curves; test thermal soak or reduce duty |
| Cost escalation | NRE, tooling, software and rework are unpriced | Quote them separately; compare a catalog solution with an adapter |
| Packaging mismatch | No bearing loads, suspension travel or service envelope model | Review CAD and tolerance stack; consider separate motor/inverter packaging |
| Delivery / compliance assumptions | No project schedule or product certificate is provided | Agree acceptance milestones and document responsibilities before an order |
Scroll horizontally to compare columns; keyboard users can focus the table region.
Hypothetical examples, calculated with the same model and constants as the tool. These are not customer deployments, measured results or approved configurations.
1,000 kg payload + 250 kg tare, 1.5 m/s, 1 s acceleration, 3% ramp, 200 mm wheels, 2WD and 48 V.
Next step: Measure ramp grip and turn scrub, then obtain a motor/gear curve at the calculated wheel speed.
3,500 kg payload + 800 kg tare, 1.2 m/s, 1.5 s acceleration, 5% ramp, 250 mm wheels, 2WD and 80 V; cycloidal transmission assumed.
Next step: Add steering-axis demand and low-battery current; review insulation, protection and chassis load paths.
300 kg payload + 120 kg tare, 2.5 m/s, 0.8 s acceleration, flat floor, 160 mm wheels and 48 V; 65% driven load.
Next step: Check traction reserve and stopping energy at full charge. Do not infer resistor or brake ratings from peak watts.
As reviewed on 2026-11-02, Regulation (EU) 2023/1230 generally applies from 20 January 2027. Check the applicable placing-on-market date and provisions. Do not automatically classify every drive as partly completed machinery: agree the supplied scope, classification and required documentation with the supplier and vehicle integrator.
This guide and calculator are not a conformity assessment. Request evidence for the exact supplied variant and document the vehicle-level responsibilities.
EUR-Lex source and scope ↓Define the scope in the RFQ: wheel, bearings, transmission, motor, inverter, sensors, brake, harness, firmware and interfaces. Inclusion is project-specific; the calculator records a concept request rather than a supplied configuration.
Consider custom development when the envelope, load path or interface cannot be met by a documented catalog configuration. Compare adaptation costs, NRE, service support and validation effort before committing.
It is wheel-output torque per driven wheel. Motor torque requires an actual gear ratio and transmission efficiency. The tool does not choose a motor or a gearbox rating.
It provides indicative straight-line demand with equal traction sharing. Mecanum roller losses, lateral force vectors, steering motors, scrub and chassis load transfer are outside the model and need separate calculations.
At unchanged electrical power, current is inversely proportional to DC voltage. Compare the complete battery and drive voltage ranges, regenerative limits and protective design rather than nominal voltage alone.
No. Cable and fuse selection also needs installation method, temperature, bundling, length, voltage drop, fault current, connector ratings and applicable requirements. No wire gauge is recommended here.
No cycle time is inferred. Confirm supported drive modes, data mapping, master capability, firmware and node count, then measure latency and fault response on the intended network.
No. It is a cruise-only scenario: steady DC current times the illustrative running fraction times operating hours. It excludes acceleration, steering, controls, lifting, idle demand and usable-capacity limits.
STO prevents torque generation but does not establish a holding brake or electrical isolation. Define and verify separate stopping, holding and service-isolation measures using the actual equipment safety manuals.
The tool cannot decide this. Compare returned energy with battery acceptance and the drive regeneration limits. Where a resistor is needed, check resistance, pulse energy, peak power, average duty and protection against the selected drive manual.
No. Safety selections are requested targets. Product certificates, vehicle risk assessment, integration and validation determine achieved performance. Machinery supply classification and documentation must be agreed for the delivered assembly and applicable date.
Send the concept brief, route and duty cycle, CAD envelope, axle loads, floor conditions, minimum and maximum battery voltage, BMS charge limits, controller details and required acceptance tests. Price and delivery remain to be quoted.
Reviewed 2026-11-02. Sources support the specific scope described below. Calculator constants and procurement frameworks are declared assumptions, not values endorsed by these organizations. No independently verified supplier performance, product certification or project schedule is available on this page.
Public scope: safety requirements and verification for driverless trucks and systems. It does not validate these sizing assumptions or certify a drive assembly. Full normative clauses require the applicable standard.
Manufacturer guidance: STO is not electrical isolation. Use the selected drive manual and safety certificate to establish its actual function and integration constraints.
Manufacturer method for a linear axis: separate peak braking power and cycle-average resistor power. It does not establish battery charge acceptance or resistor ratings for this vehicle.
Describes drive states, modes and process data; optional feature coverage varies. A profile name alone does not establish device interchangeability or an achievable bus cycle.
General application of Regulation (EU) 2023/1230 begins 20 January 2027. Check the applicable provisions and placing-on-market date; supply classification depends on the delivered assembly.
Copy the tool brief, attach the mission cycle and CAD envelope in your engineering process, and submit the requirements through our inquiry form. Confirm hardware, validation scope, price and schedule with engineering.